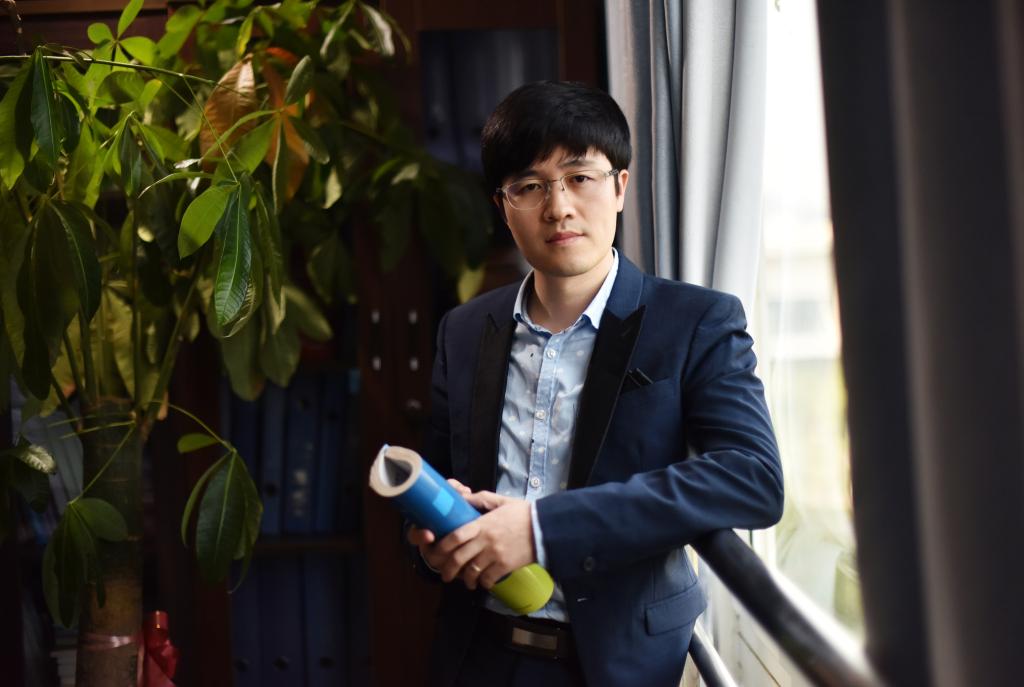
付荣 副教授
博士,硕士生导师,男,汉族,1982年6月出生,福建省三明市宁化县人。厦门理工学院自动化系主任。
联系方式:
furongfj007@163.com;furong@xmut.edu.cn
研究方向:
飞行器控制、非线性时变系统控制、容错控制
学科专业:
控制科学与工程、自动化
教育背景与工作经历:
2025年12月至今,厦门理工学院,副教授
2019.2-2025.11,厦门理工学院,讲师
2013.9-2018.9 厦门大学航空航天学院控制理论与控制工程专业,博士;
2009.7-2013.6 福州理工学院,助教、讲师;
2006.9-2009.6厦门大学信息科学与技术学院控制理论与控制工程专业,硕士;
2005.3-2006.8 厦门松下电子信息有限公司,电气工程师;
2004.8-2004.10 福建华擎发动机工业有限公司,电气工程师;
2000.9-2004.6 中南大学信息科学与工程学院自动化专业,本科
学术兼职:
厦门市自动化学会理事;
核电安全监控技术与装备国家重点实验室客座助理研究员(中广核集团);
长期担任IEEE/CAA Journal of Automatica Sinica、IEEE Transactions on Industrial Informatics、IEEE Transactions on Power Electronics、Journal of Guidance, Control, and Dynamics、International Journal of Robust and Nonlinear Control、International Journal of Control、ISA Transactions、Journal of the Franklin Institute、Journal of Nonlinear Science、Transactions of the Institute of Measurement and Control及《北京航空航天大学学报》等期刊审稿人
讲授课程:
现代控制理论(国家一流课程)、运筹学(省级一流课程)、最优化导论、自适应控制(研究生)
科研及教学成果:
学术论文:
[1] Fu R, Zeng J*, Duan Z. H∞ mixed stabilization of nonlinear parameter-varying systems [J]. International Journal of Robust and Nonlinear Control, 2018, 28(17): 5232-5246. (SCI, JCR Q1, IF=3.953)
[2] Fu R, Sun H, Zeng J*. Exponential stabilization of nonlinear parameter-varying systems with applications to conversion flight control of a tilt rotor aircraft [J]. International Journal of Control, 2019, 92(11): 2473-2483. (SCI, JCR Q2, IF=2.93)
[3] Fu R, Zeng J*, Wang Y, Zhang D. Conversion flight control for tilt rotor aircraft using nonlinear time-varying perspective [J]. Journal of Aerospace Engineering, 2020, 33(5): 0402006. (SCI, JCR Q2, IF=2.4)
[4] Lu L, Fu R, Zeng J*, Duan Z. On the domain of attraction and local stabilization of nonlinear parameter-varying systems [J]. International Journal of Robust and Nonlinear Control, 2020, 30(1): 17-32. (SCI, JCR Q1, IF=3.953)
[5] 鲁麟宏, 付荣, 王勇, 曾建平*. 基于矫正广义走廊的电动倾转旋翼机模态转换 [J]. 航空学报, 2018, 39(8): 121900. (EI收录)
[6] 周燕茹*, 汪育成, 付荣. 一类具有凸多面体不确定性的非线性变参数系统鲁棒H∞控制 [J]. 控制理论与应用, 2023, 40(06): 995-1004. (EI收录)
[7] 蔡系海, 付荣, 曾建平*. 倾转旋翼机模态转换的鲁棒H∞增益调度控制 [J]. 厦门大学学报(自然科学版), 2016, 55(3): 382-389.
[8] 付荣*, 曾建平. 稳定化的有限频段H∞控制及有限频段跟踪问题 [J]. 计算机工程与应用, 2013, 49(6): 240-244
[9] Fang Z, Zhou Y, Fu R*. H∞ Mixed Stable Fault Detection Observer for Nonlinear Parameter-Varying Systems [C]//2025 37th Chinese Control and Decision Conference (CCDC). IEEE, 2025: 2210-2215. (EI收录)
[10] Chen Y, Fu R*, Lin Y. Non-Certainty-Equivalence Adaptive Fault-Tolerant Control for Nonlinear Parameter-Varying Systems [C]// 2025 37th Chinese Control and Decision Conference (CCDC). IEEE, 2025: 2216-2221. (EI收录)
[11] Lei Y, Fu R*. Disturbance-Observer-based Fast Terminal Sliding Mode Control for Quadrotor UAVs [C]//2023 35th Chinese Control and Decision Conference (CCDC). IEEE, 2023: 953-958. (EI收录)
[12] Zeng Z, Fu R*. Research on Adaptive Control Approach of Firefighting UAVs with Fire-Extinguishing Bombs [C]//2022 China Automation Congress (CAC). IEEE, 2022: 3722-3726. (EI收录)
[13] Li W, Fu R*, Zhao C, et al. Fixed-time fault-tolerant control of spacecraft based on adaptive non-singular terminal sliding mode [C]//2022 China Automation Congress (CAC). IEEE, 2022: 3534-3540. (EI收录)
[14] Lin Y, Fu R*, Xie Z, et al. H∞ Mixed Stabilization Based on High Order Disturbance Observer with Application to An Active Suspension Control System [C]//2023 42nd Chinese Control Conference (CCC). IEEE, 2023: 576-580. (EI收录)
[15] Xie Z, Fu R*, Lin Y. Attitude Stabilization Control of Flexible Spacecraft Based on High-Order Disturbance Observer Using Nonlinear Parameter-Varying Perspective [C]//2022 China Automation Congress (CAC). IEEE, 2022: 3087-3092. (EI收录)
[16] Zhao C, Fu R*, Li W. Composite Hierarchical Anti-Disturbance Control for Nonlinear Polynomial Systems with Applications to Active Suspension Control Systems [C]//2022 China Automation Congress (CAC). IEEE, 2022: 4018-4023. (EI收录)
[17] Fu R, Zhou Y, Zeng J*. Disturbance-observer-based nonlinear stabilization control of flexible spacecraft attitude system [C]//Proceedings of the 34th Chinese Control Conference. IEEE; Hangzhou, China: 2015: 1212-1216. (EI收录)
[18] Lin H, Fu R, Zeng J*. Extended state observer based sliding mode control for a tilt rotor UAV [C]//Proceedings of the 36th Chinese Control Conference. Dalian, China: IEEE, 2017: 3771-3775. (EI收录)
教学成果及获奖:
[1] 2020年,《现代控制理论》获批国家级一流本科课程,排名第2;
[2] 2020年,《运筹学》获批福建省一流本科课程,主持;
[3] 2023年,《运筹学》入选福建省新工科优秀教学案例,主持;
[4] 2021年,《现代控制理论》入选省级课程思政示范课程,排名第2;
[5] 2024年,获福建省教学成果二等奖,排名第7;
[6] 2022年,获福建省教学成果二等奖,排名第3;
[7] 2021年,获福建省慕课与线上线下混合式教学案例一等奖,排名第2;
[8] 2019年,《现代控制理论》入选省级精品线上下混合式课程,排名第2;
[9] 2022-2023学年度,校优秀教师;
[10] 2025年,指导2025届研究生曾泽杭论文《非线性变参数系统的自适应故障补偿控制方法研究》,获得2024-2025学年校级优秀硕士学位论文;
[11] 2024年,指导2024届研究生解振宝论文《执行器故障下非线性变参数系统被动容错控制》,获得2023-2024学年校级优秀硕士学位论文;
[12] 2022年,校级教师教学创新大赛二等奖;
[13] 2024年,校级教学成果特等奖,排名第4;
[14] 2021年,校级教学成果一等奖,排名第3;
主持或参与课题:
[1] 2024.11-2027.11,主持福建省自然科学基金面上项目——“倾转旋翼无人机过渡阶段复合容错飞行控制方法研究”,2024J011204,9万
[2] 2020.8-2023.8,主持福建省自然科学基金面上项目——“倾转四旋翼垂直起降固定翼无人机过渡阶段飞行控制方法研究”,2020J01284,7万
[3] 2019.12-2022.11,主持福建省教育厅中青年教师教育科研项目——“基于凸优化的非线性时变飞控系统设计方法”,JAT190655,1万
[4] 2017.1-2017.12,参与国家自然科学基金面上项目——“倾转旋翼飞行器模态转换阶段非线性控制方法研究”,61673325,16万,负责非线性时变控制方案设计,主要参与人
[5] 2014.1-2017.12,参与国家自然科学基金面上项目——“挠性卫星姿态动力学系统非线性控制新方法研究”,61374037,80万,负责基于扰动观测的控制方案设计
[6] 2016.2-2016.12,参与北京航空航天大学委托项目——“无人机刚弹一体化飞行控制理论和方法”,XDHT2016070A,15万,负责扰动观测器方案设计
[7] 2014.4-2015.12,参与北京航空航天大学委托项目——“倾转旋翼无人机鲁棒控制方法研究”,XDHT2014336A,15万,负责鲁棒非线性控制方案设计,主要参与人
研究生培养情况:
指导电子信息专业(控制工程方向)硕士研究生9人,已毕业6人,在读3人


